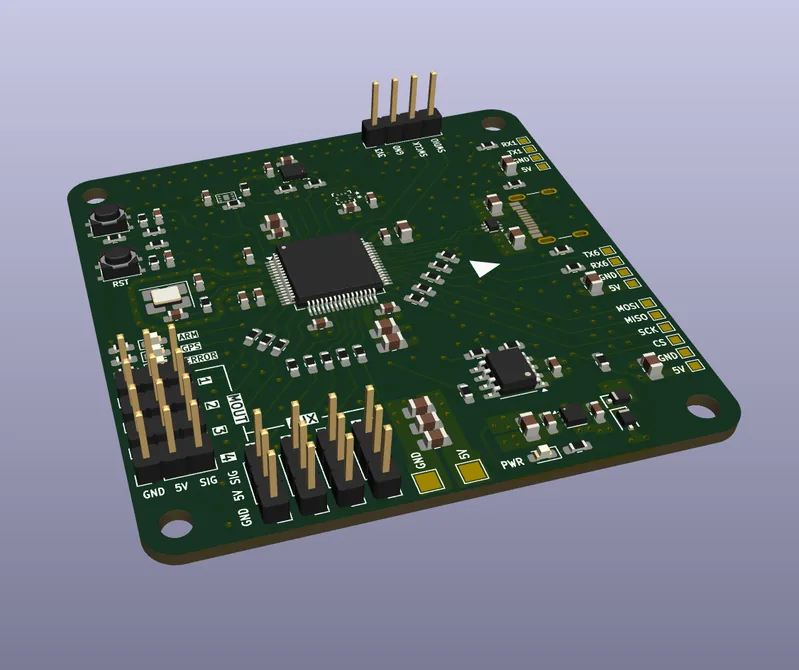
A custom STM32-based flight control board and stabilisation firmware.
Role
Board design and firmware
MCU
STM32
Software
FreeRTOS, PID
Status
Being documented
06.1Summary
A flight control board designed around an STM32 microcontroller. The board carries GND-5V-SIG headers for ESC/servo outputs, separate UARTs for receiver and telemetry, an SPI header for external sensors, and status LEDs. On the firmware side it targets PID control and IMU sensor fusion on FreeRTOS.
In the same period I also worked on image processing and route tracking with OpenCV for an autonomous UAV.
Fig. 13D view — 3D render of the board.
Schematic, specifications and test results for this page are being prepared.